We build machines that build the world.
Rift builds robots for the slow, repetitive, exposed work of construction. The first, Spider Monkey, works on the utility pole line.
Most of what gets built is still built by hand: at height, beside traffic, in the weather, one repeated task at a time. We build machines for that work.
Slow by construction
Much of the time on a site goes to getting people and equipment into position. The task itself is often the short part.
Repetitive work in exposed places
The tasks that repeat most are often the ones done at height or beside traffic. Those are the ones to hand to a machine.
Starting on the pole line
Our first machine strings new line on utility poles. It works from the pole and the strand, and leaves the street alone.
The first machine.
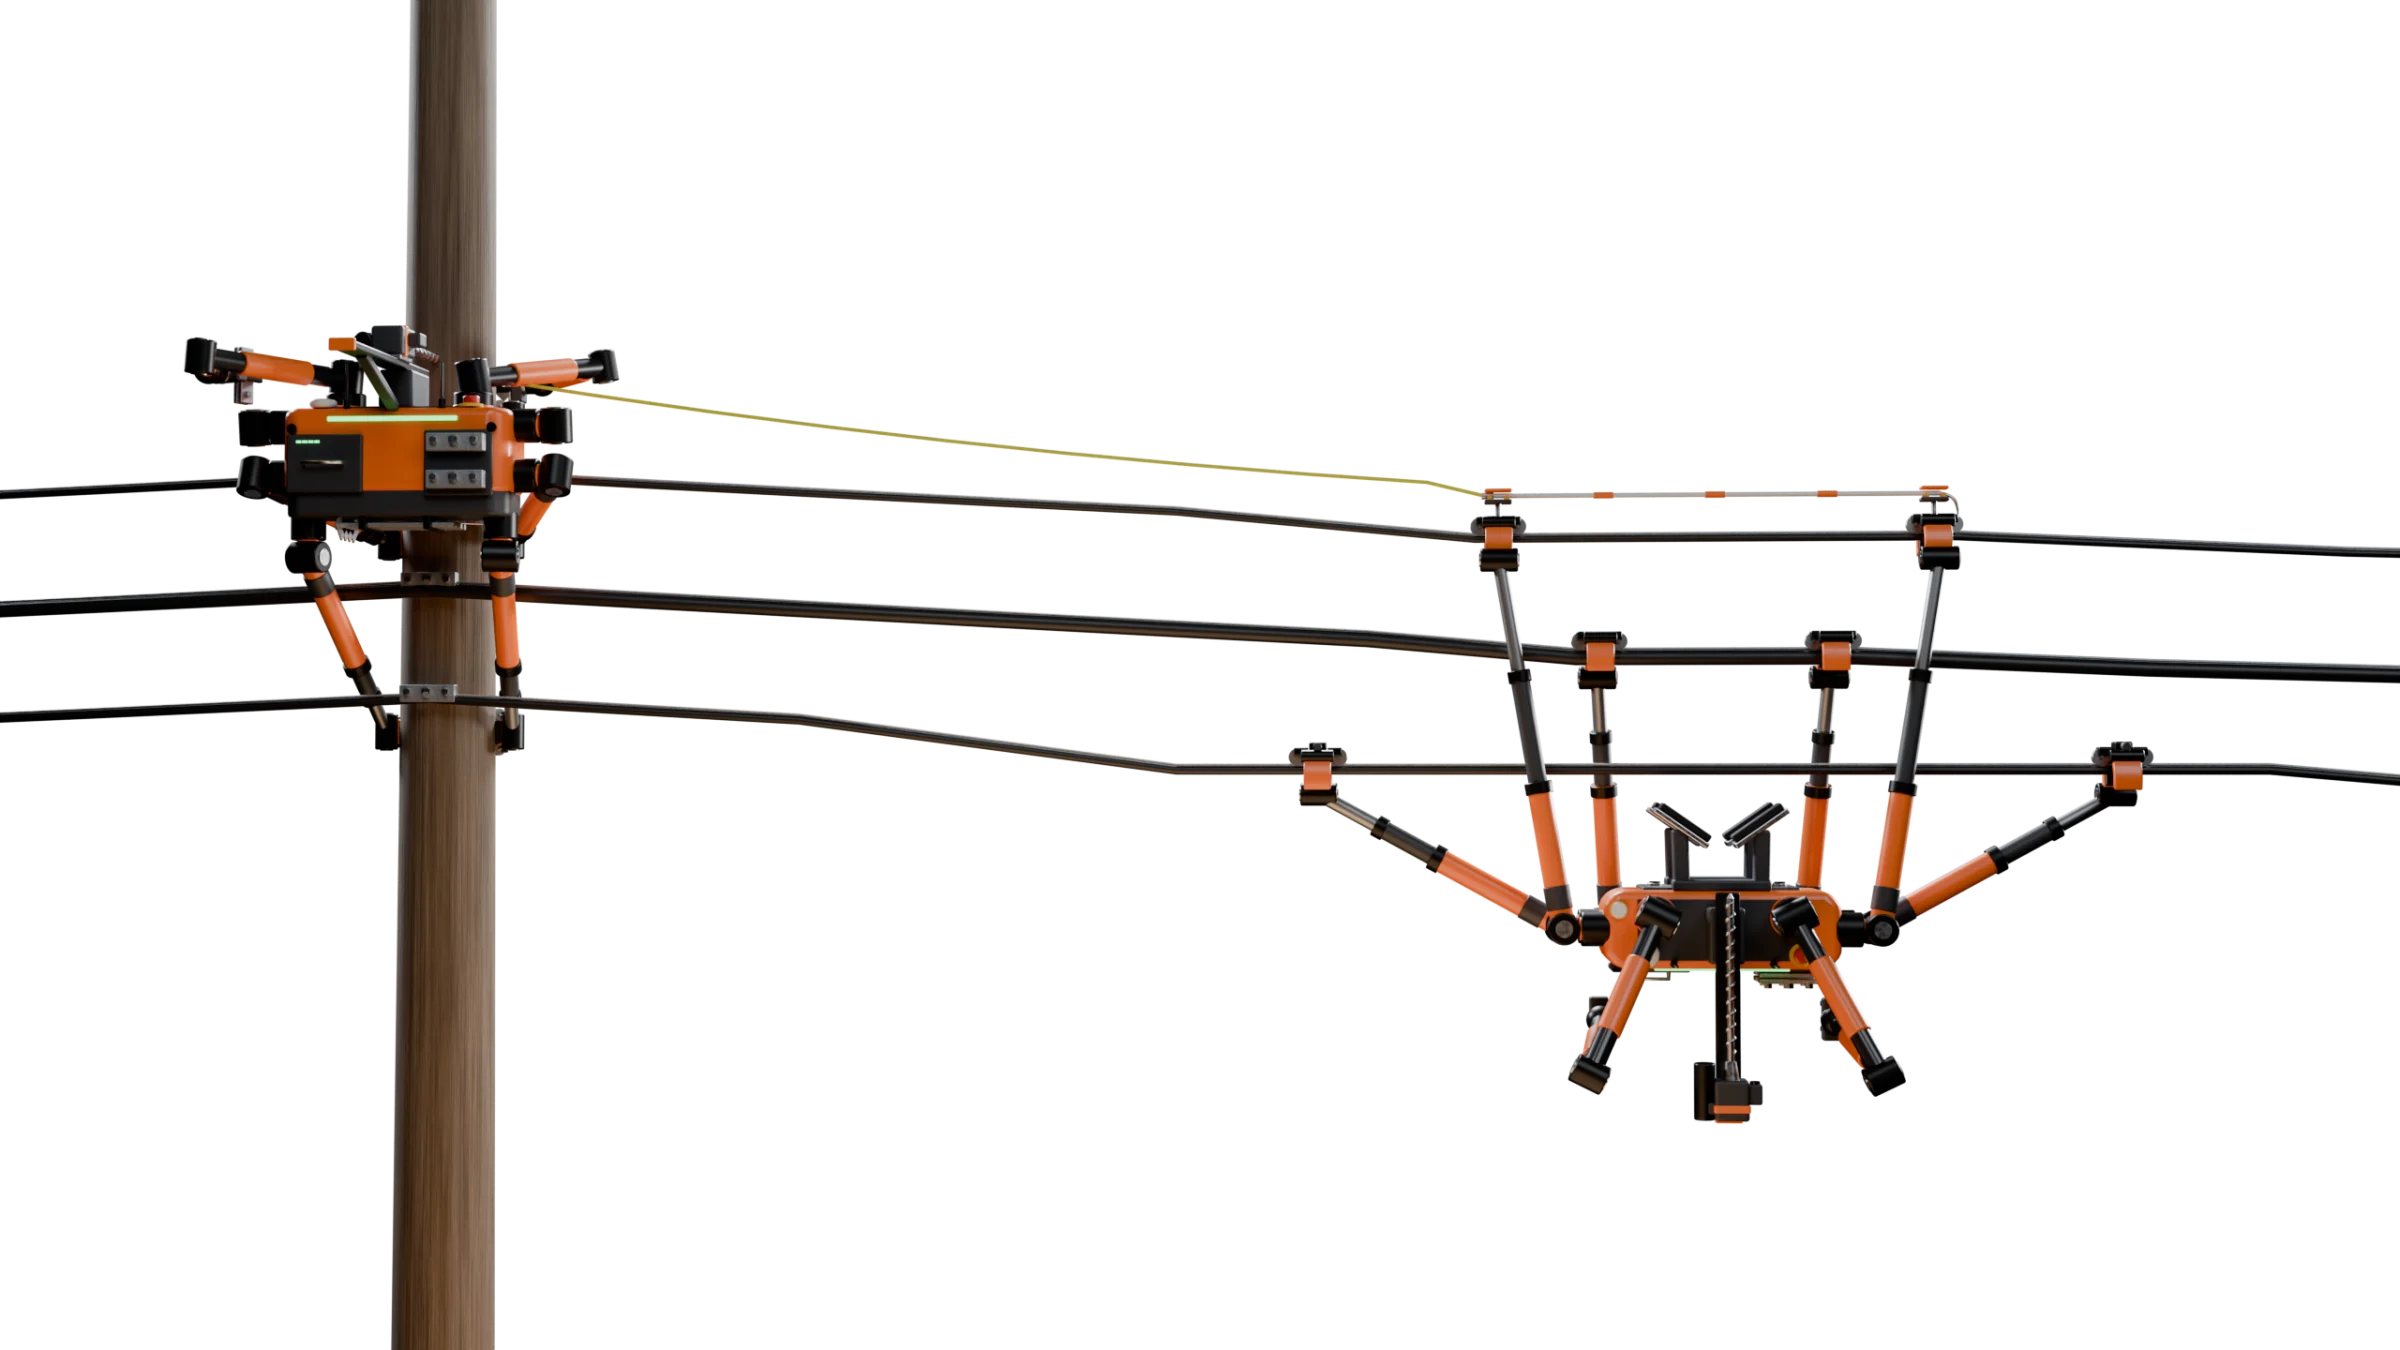
Spider Monkey strings new line on utility poles. It climbs the pole, sets the hardware, then crosses the span on the lines that are already there.

Six limbs, each a leg and a handThey clamp the pole to climb, then hook over the strand to cross.
Steel onlyThe pulling hands close on bare steel strand. The cable underneath is never squeezed.
Drill on topIt bores the pole and sets the bolt for the new attachment, above everything already there.
Built to work from the line.Not from the lane.
Two machines work a route as a pair. One sets the hardware at the pole while the other takes the pull line across the span. The crew stays on the ground, in charge.
A person isalways incommand.
Every Rift machine works under a field supervisor who can stop it, or take over and drive it, at any moment. Override is not a feature we added. It is how our machines are meant to be run.
- TeleoperationThe operator drives every motion. The machine holds its grip and limits force.
- Step approvalThe machine proposes each step. A person approves it before it moves.
- Supervised autonomyThe machine runs a whole task. The supervisor watches, and can stop it.
Interface concept. Try Hold or Take control.
Have work a machineshould be doing?
Tell us about the slow, repetitive, exposed jobs on your sites. That is where we want to build next.